Radar-Based Sparsity-Aware Dynamic Occupancy Grid Mapping
Conference presentation on using radar Doppler and spatial structure for sparsity-aware dynamic occupancy grid mapping.
Talks, seminars, and conference presentations by Peiyuan Zhai.
Conference presentation on using radar Doppler and spatial structure for sparsity-aware dynamic occupancy grid mapping.
A tutorial on occupancy grid mapping: from Bayesian inverse sensor models to learning-based OGM, dynamic and semantic grids, sensor anomalies, and mapping-quality evaluation.
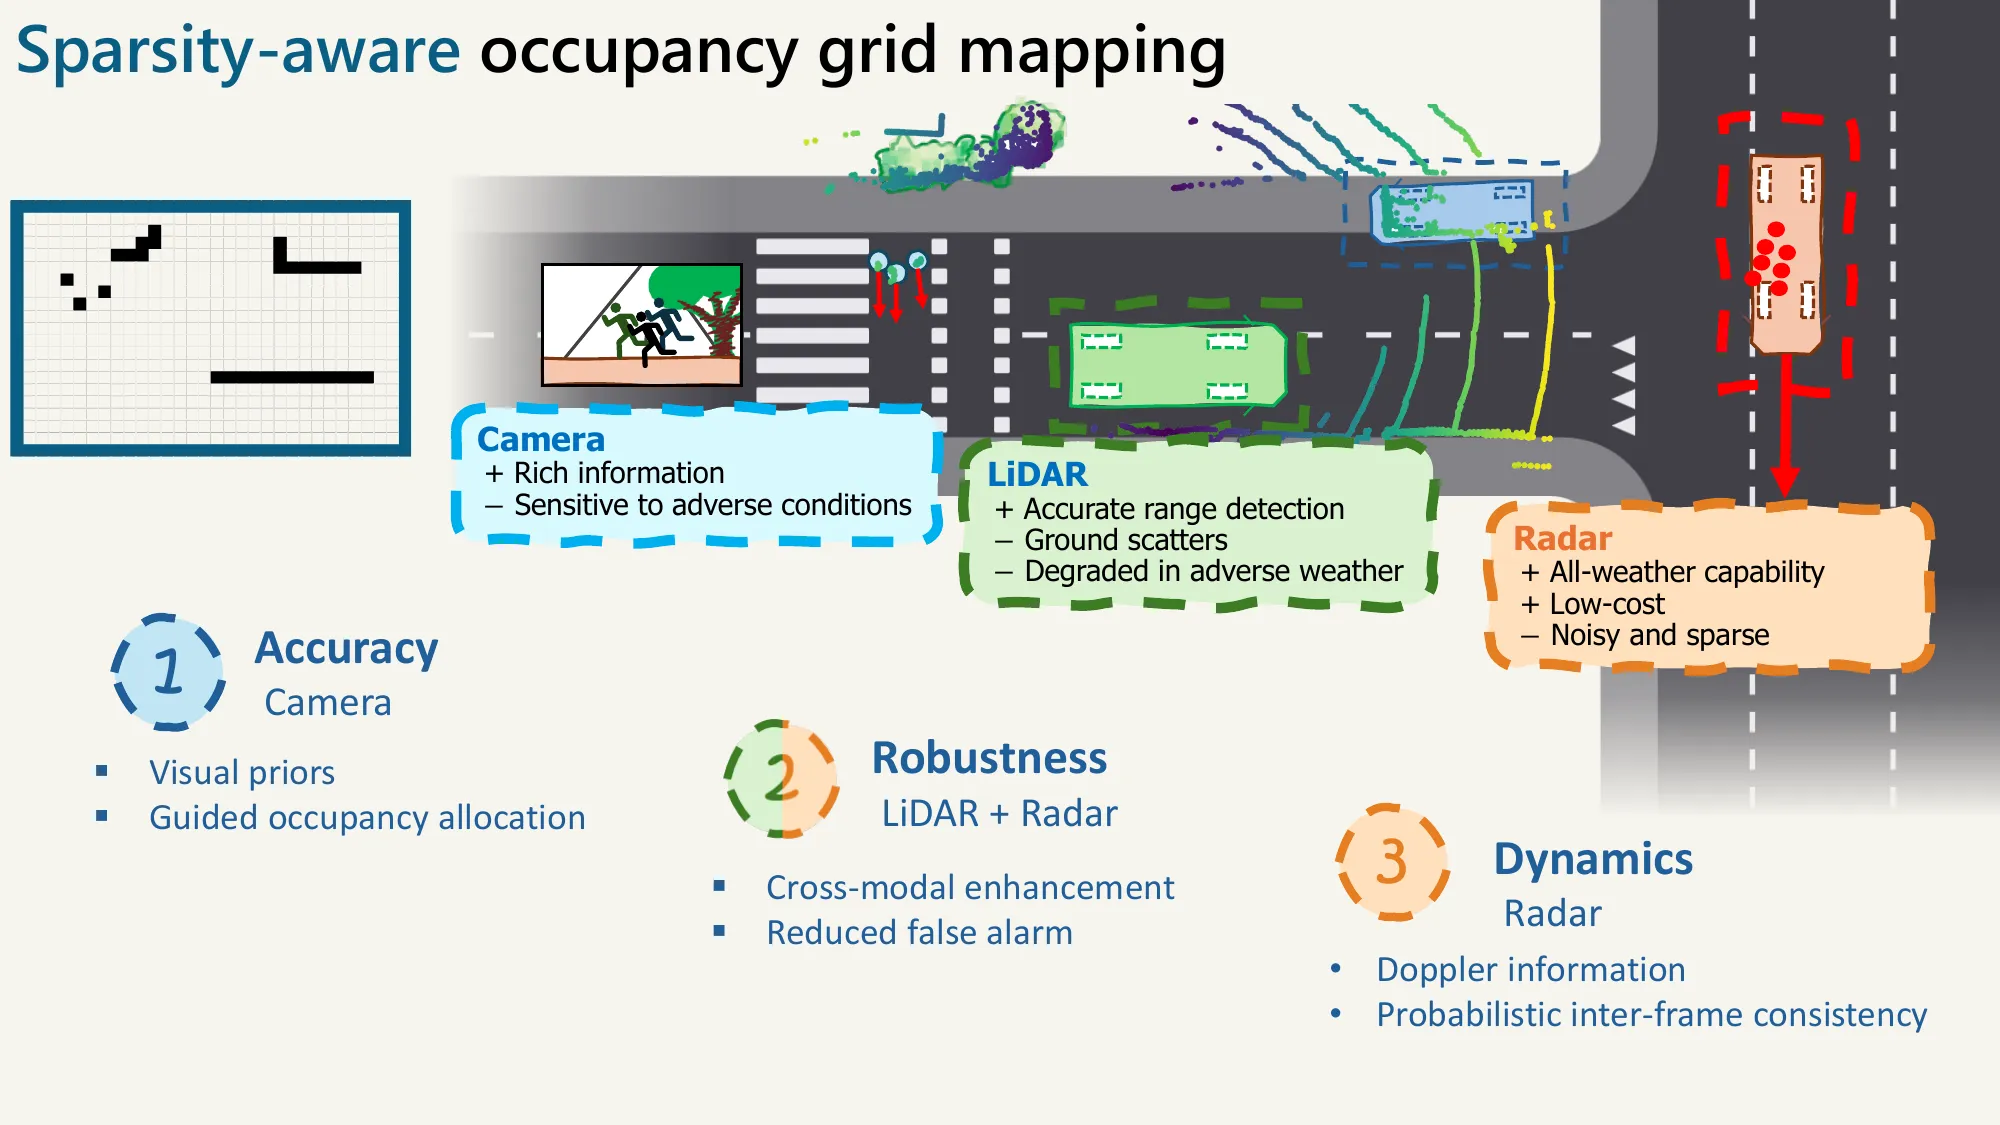
A three-minute thesis talk on combining camera, LiDAR, and radar for occupancy grid mapping in autonomous driving.
Conference presentation on fusing radar and LiDAR measurements within a sparsity-aware Bayesian framework for automotive occupancy grid mapping.